


BUILT-IN SKILL
PRIMITIVE
Composable skill units
designed for modular
scaling across tasks.
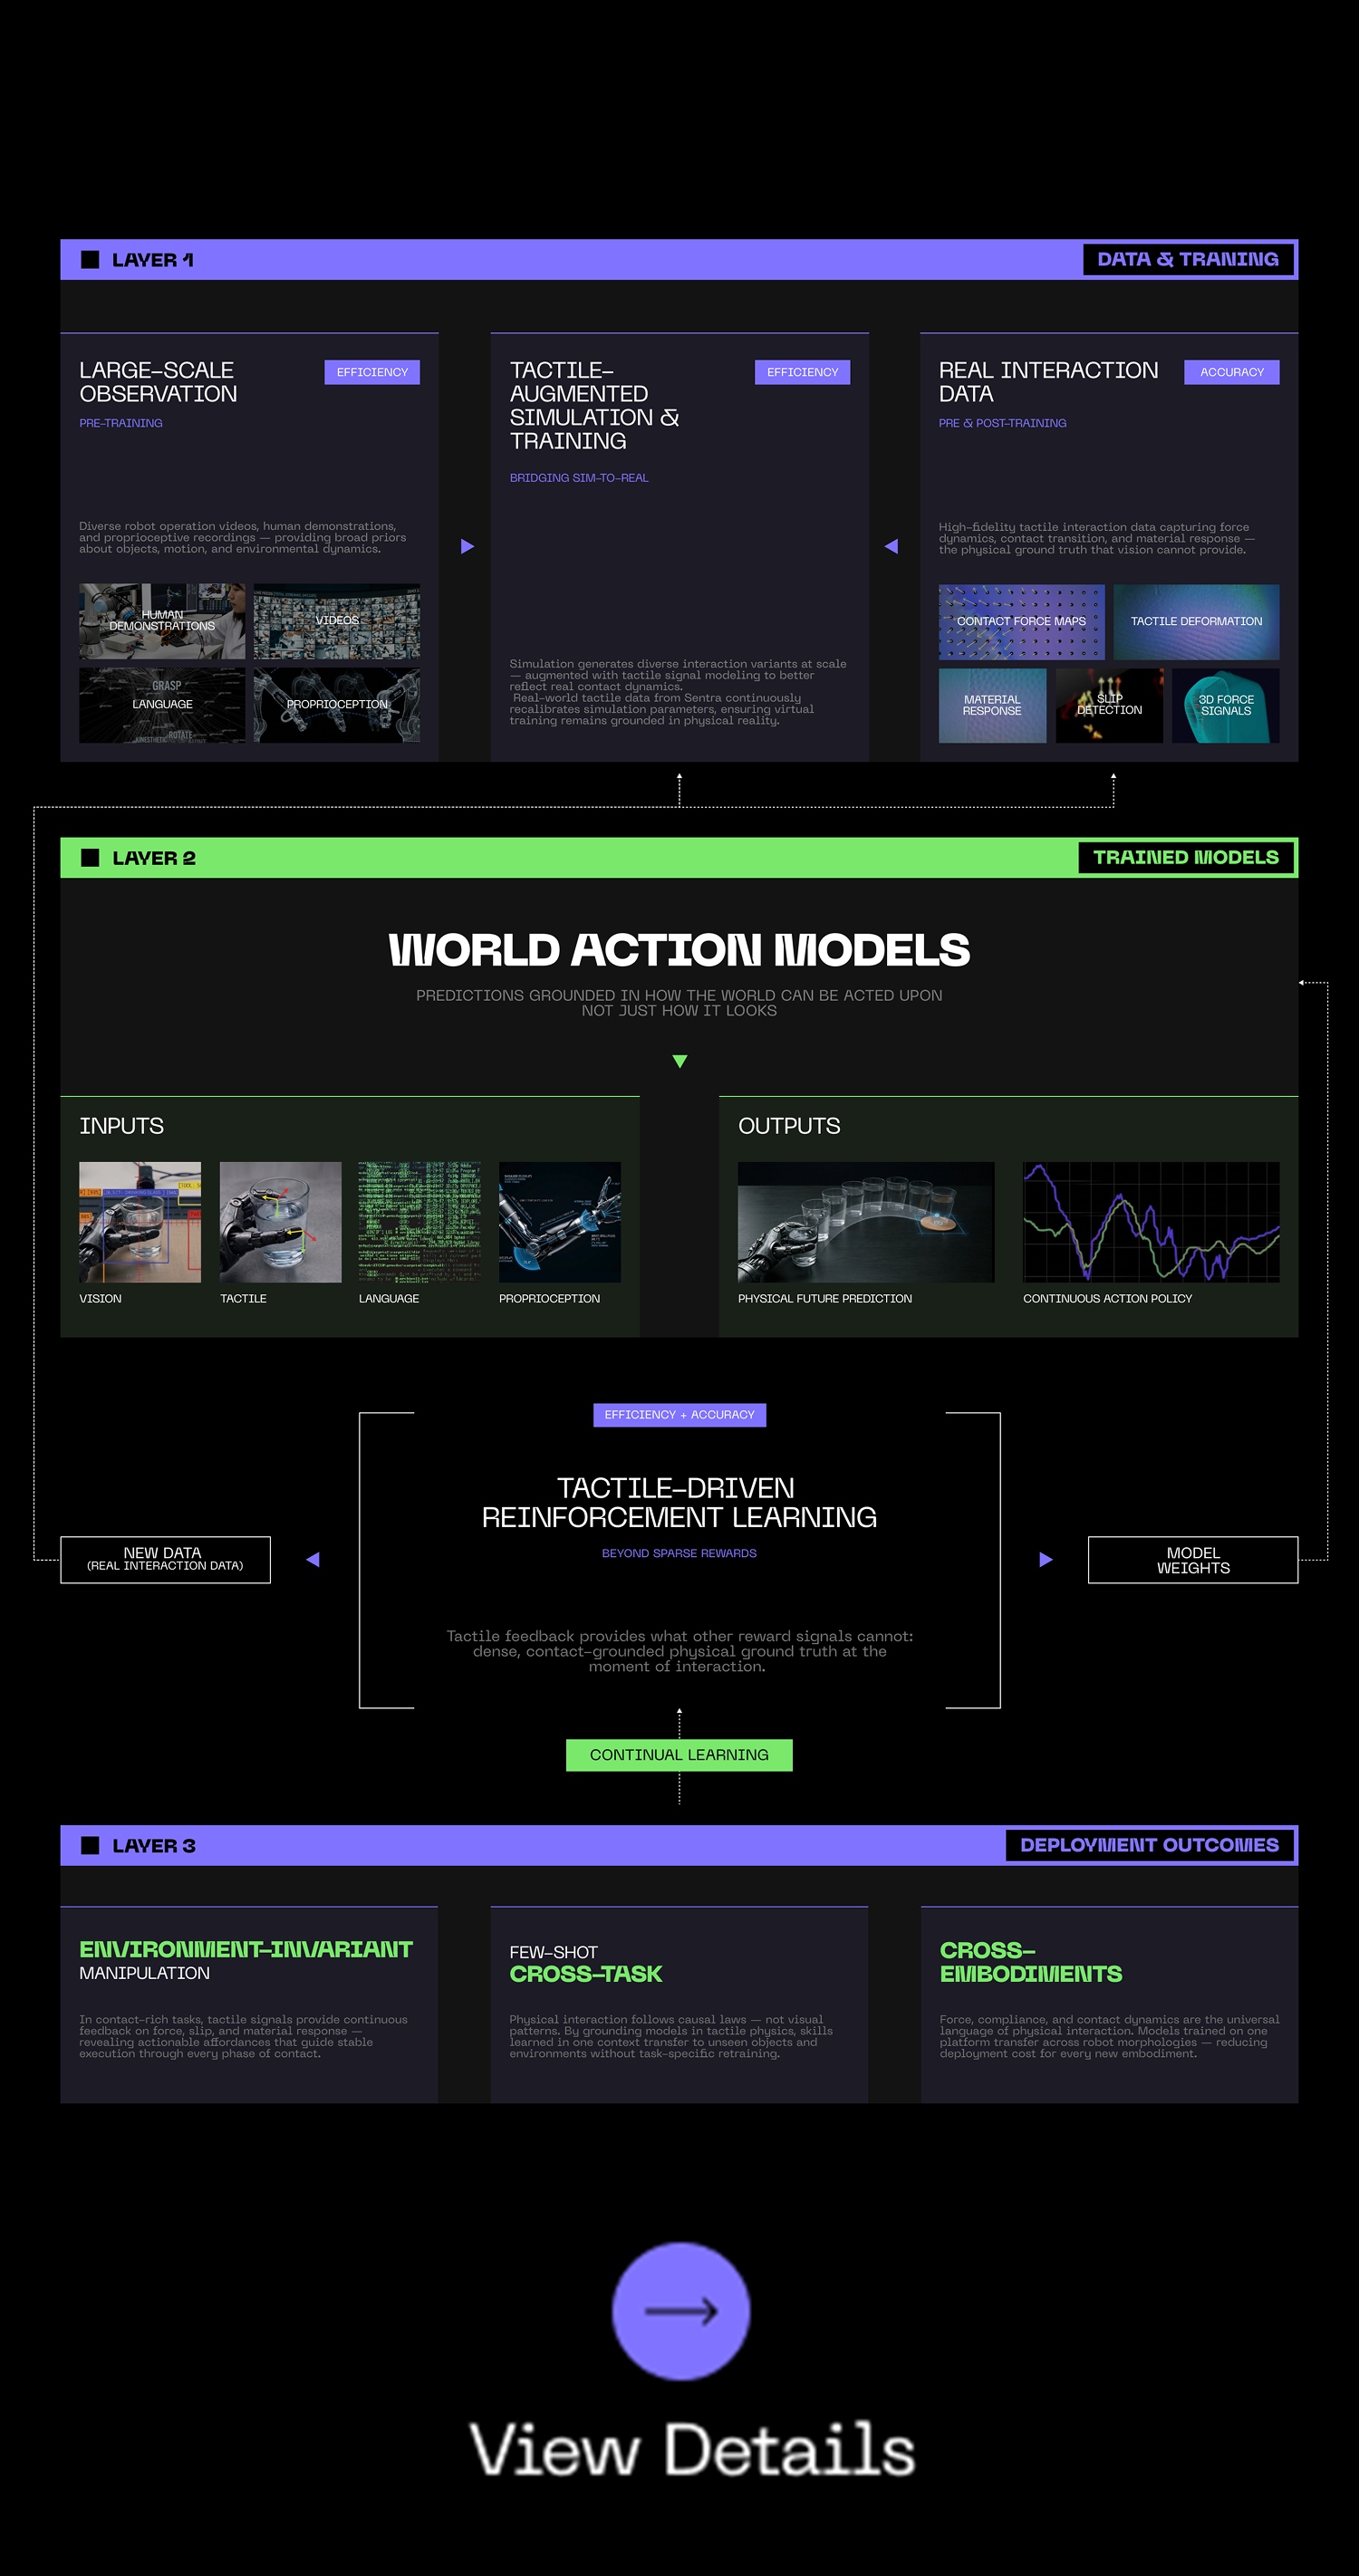
Learning physical intelligence throughobservation and interaction — enablingrobots to understand and act in the realworld, and generalize across tasks,environments, and embodiments.
INTERACTION-DRIVEN LEARNING
Learning physical intelligence through real-worldinteraction — enabling robots to manipulate,adapt, and generalize across tasks, environments,and embodiments.
Composable skill units
designed for modular
scaling across tasks.
Millisecond tactile feedback
stabilizes manipulation
behavior in real time.
Robots to perceive, plan, and act
from intent — without scripts or
task-specific programming.
A shared skill library where
manipulation intelligence
accumulates, is reused, and
continuously evolves across
deployments.